Whole-Body Tactile Representations for Motion Control
Semester project, ETH Robotic Systems Lab, 2026
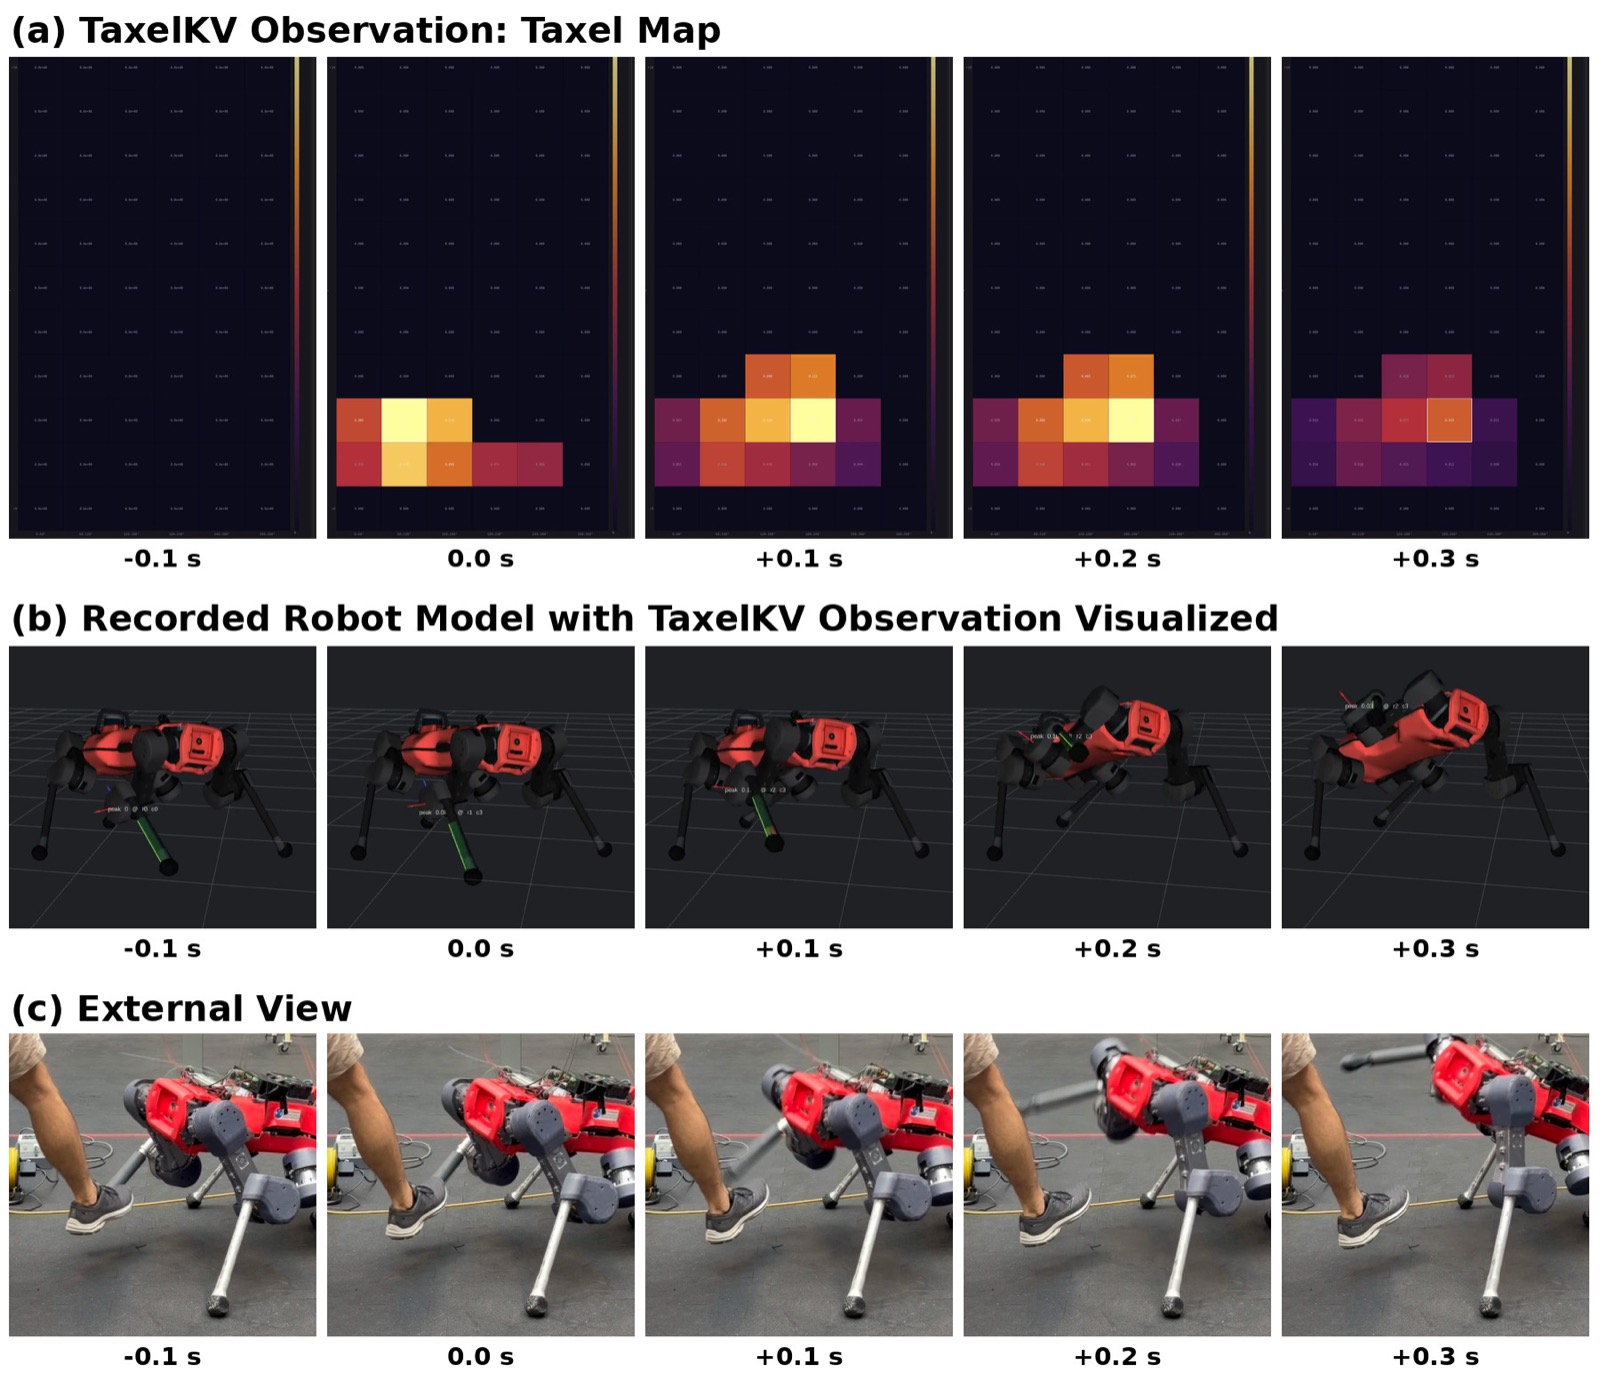
Benchmarking tactile representations for RL-based dynamic locomotion, deployed on an ANYmal-D quadruped with an FBG-based tactile skin. Semester project at the ETH Robotic Systems Lab (Spring 2026).