
I am an M.S. student in Robotics, Systems, and Control at ETH Zurich, working on legged locomotion, whole-body control, and reinforcement learning for quadruped and humanoid robots. I am currently starting my master’s thesis on motion retargeting for humanoid loco-manipulation: transferring human demonstrations that involve interactions with objects and terrain onto humanoid robots.
My research interest lies in learning whole-body behaviors for humanoid and legged robots from human motion, bridging the embodiment gap while preserving the semantic meaning of each motion. I dream of skills that transfer seamlessly to new, unseen hardware. I have deployed learned controllers on real robots, including the ANYmal-D and Unitree Go2 quadrupeds and the Booster K1 humanoid.
Before ETH, I completed my B.S. in Computer Science & Electrical and Electronic Engineering at KAIST, graduating Summa Cum Laude. My research experience there spans unsupervised skill discovery for diversifying quadruped gait patterns, hierarchical MCTS for task and motion planning, and program analysis for JavaScript engine bug detection.
You can find my full CV here, or reach me at jaerkim@student.ethz.ch.
Projects
All projects →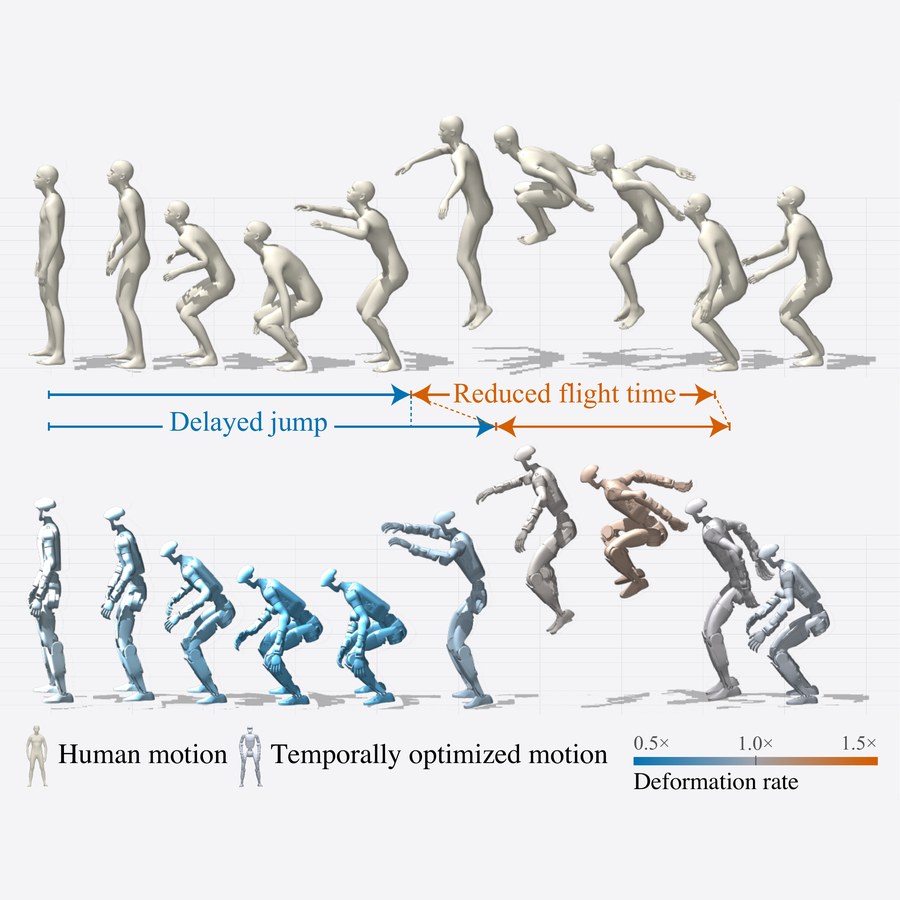
News
| Jun 26, 2026 | Our team 38° of Freedom won the robot competition at the 2026 ETH Robotics Summer School!  |
|---|---|
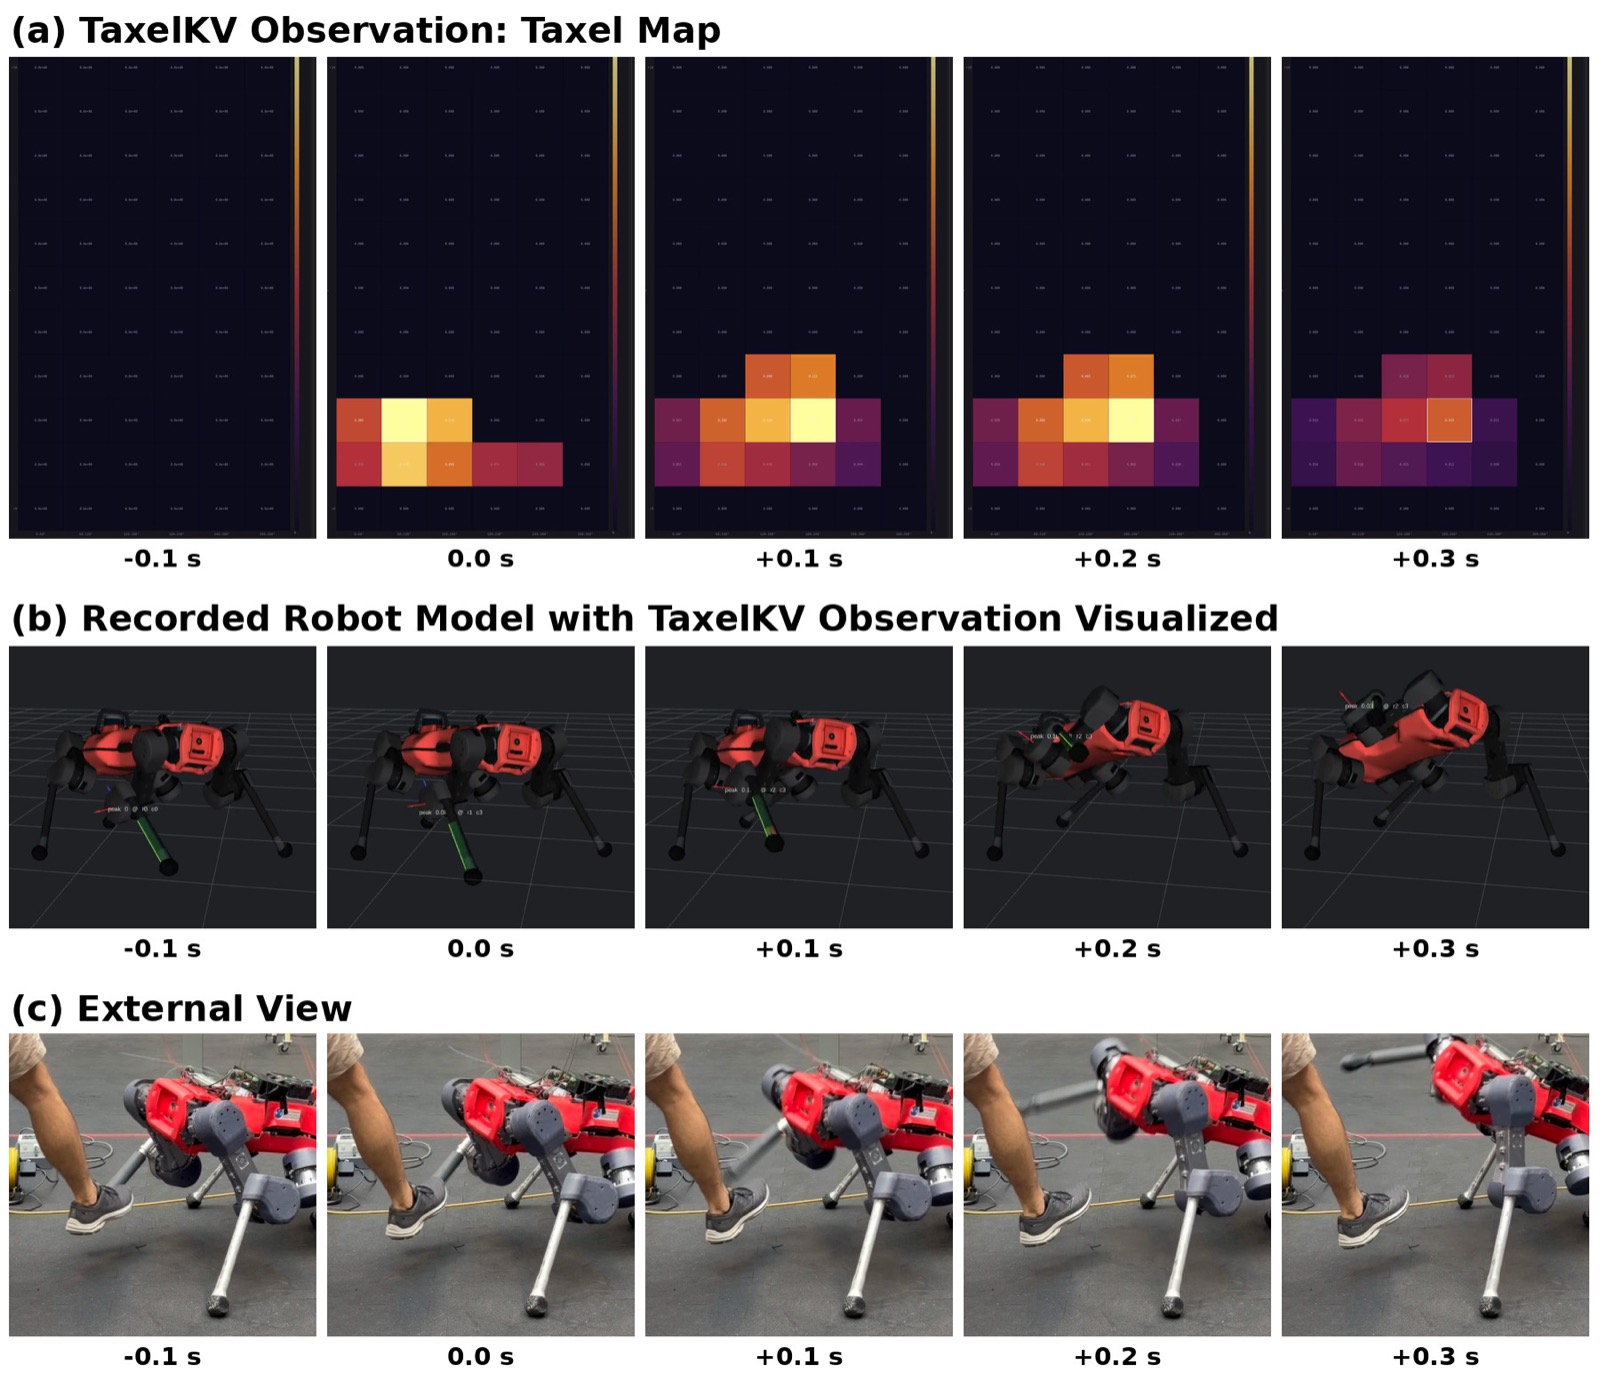
| Mar 09, 2026 | Started a semester project at the ETH Robotic Systems Lab on whole-body tactile sensing for RL-based dynamic locomotion on the ANYmal quadruped robot.  |
| Sep 15, 2025 | Started my M.S. in Robotics, Systems, and Control at ETH Zurich, and joined the Computational Robotics Lab as a research assistant working on motion retargeting and whole-body control for humanoids.  |
| Aug 29, 2025 | Graduated from KAIST with a B.S. in Computer Science & Electrical and Electronic Engineering, Summa Cum Laude.  |